UAV & Avionics · Completed
SUAV Avionics and Ground-Control System
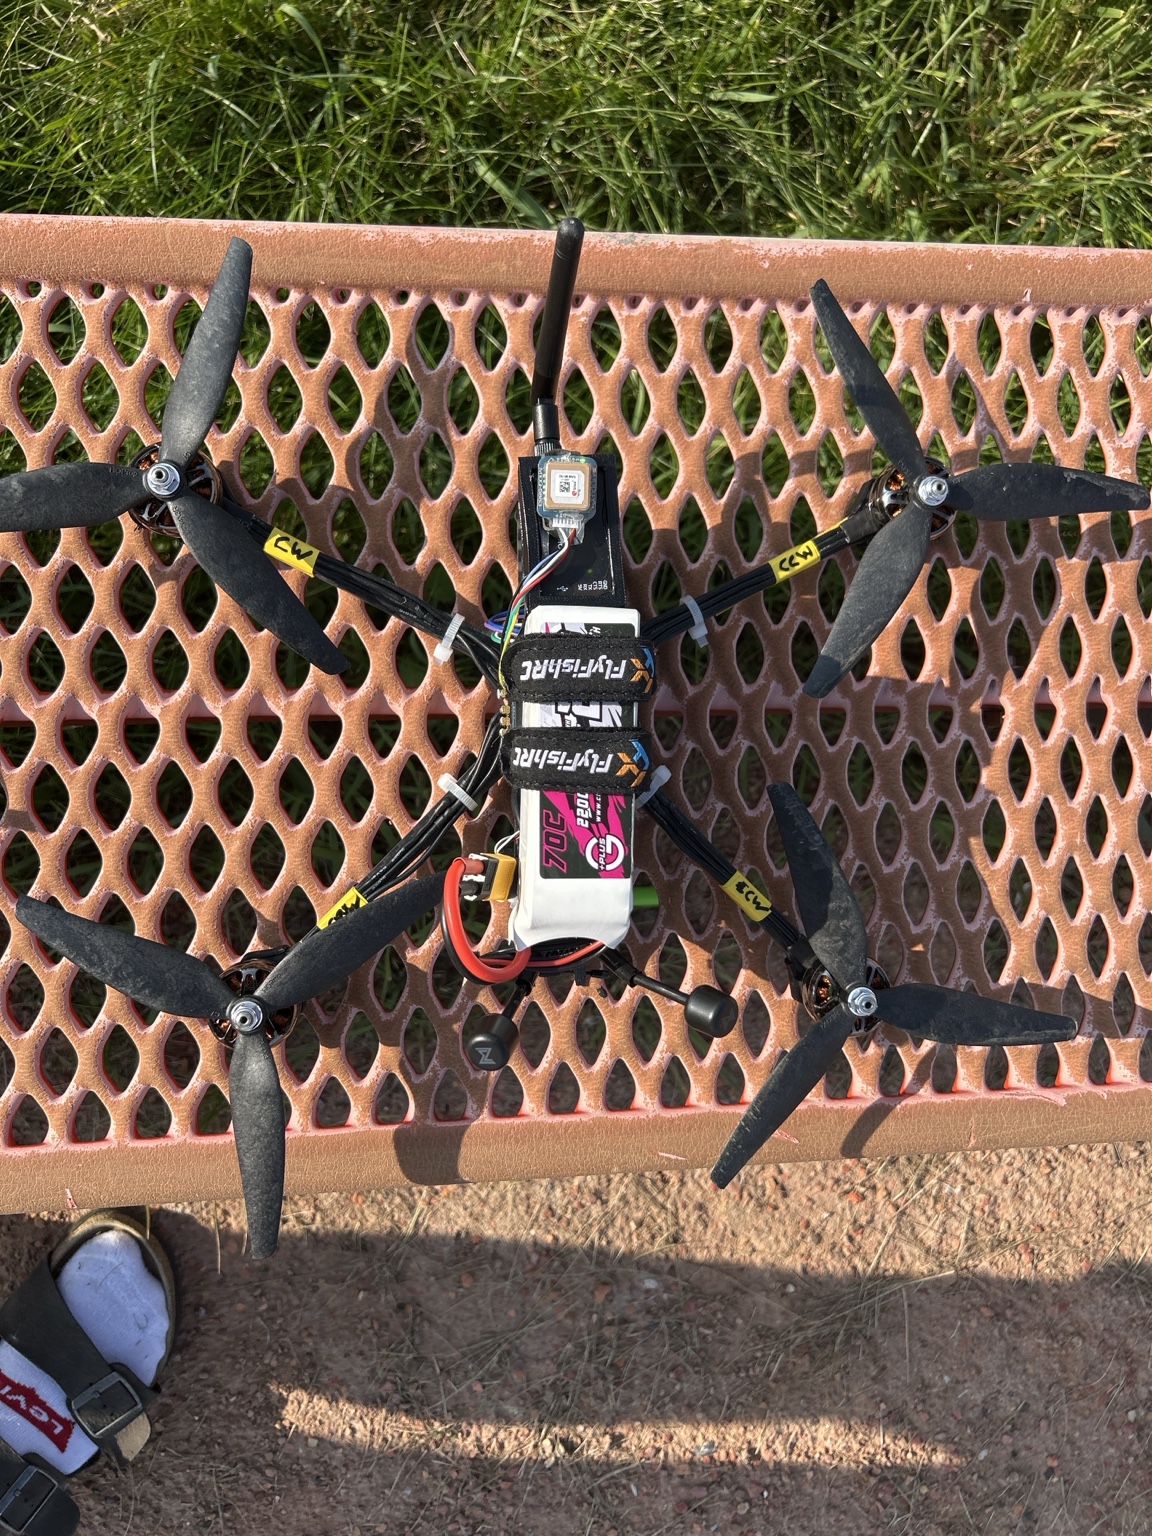
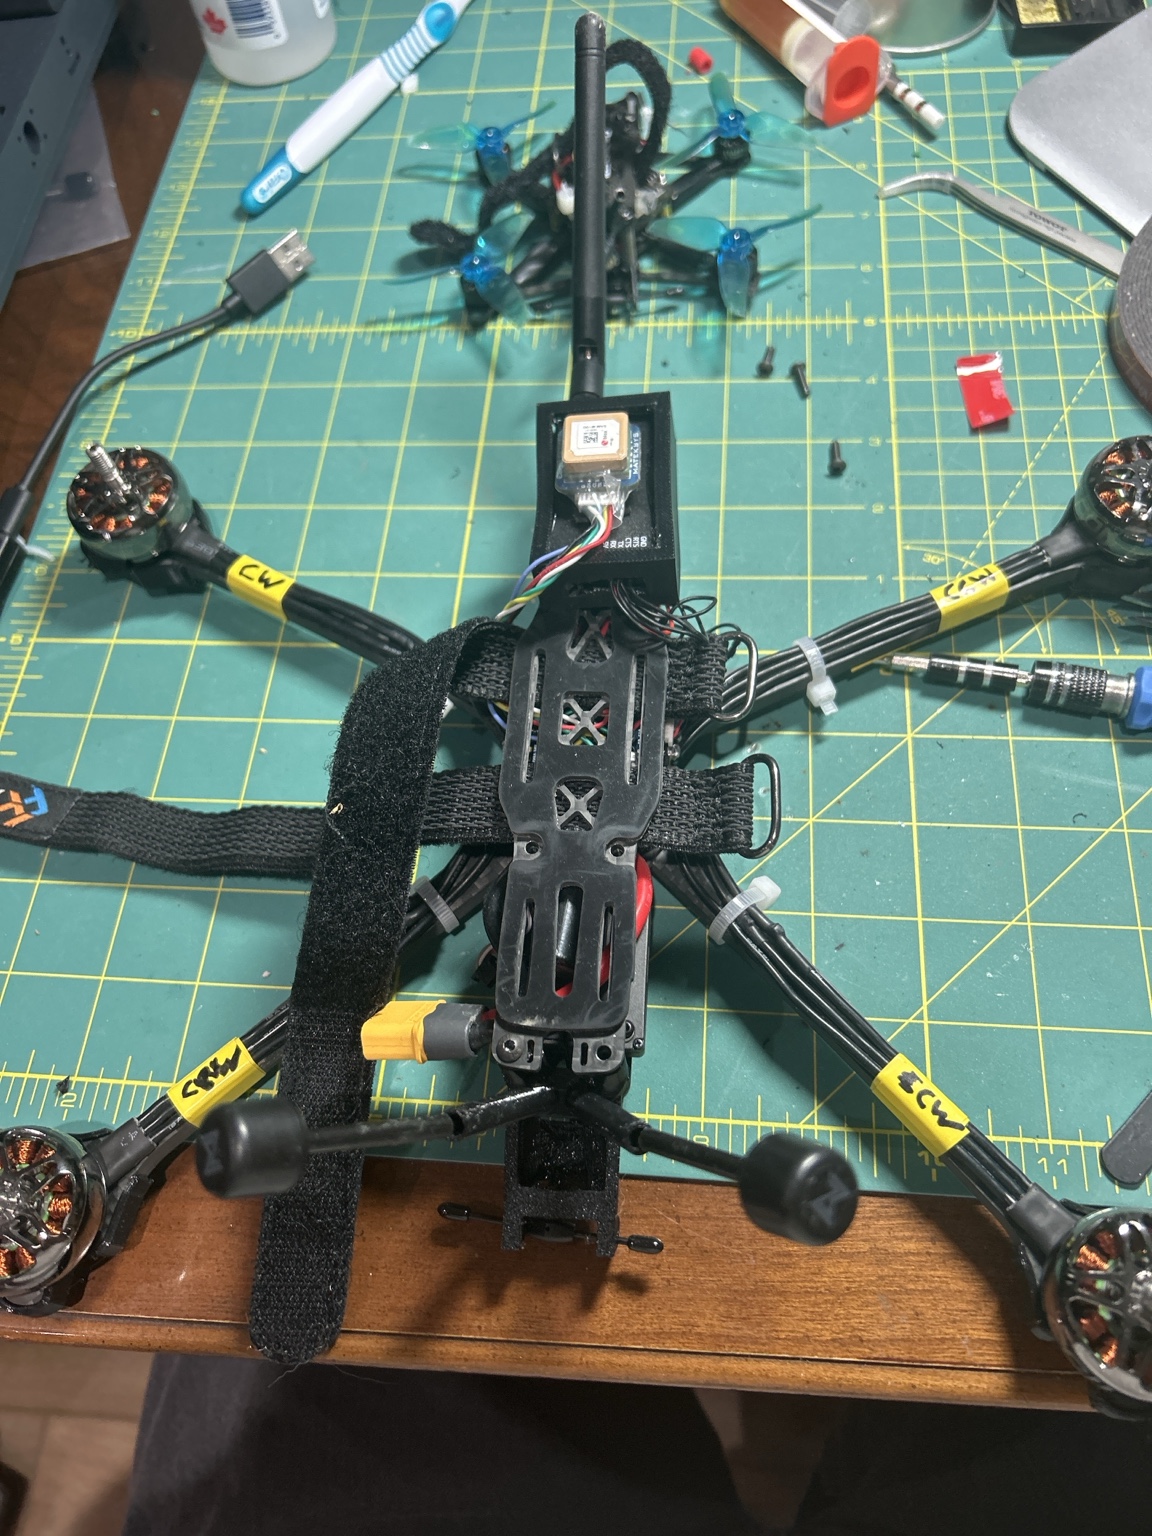
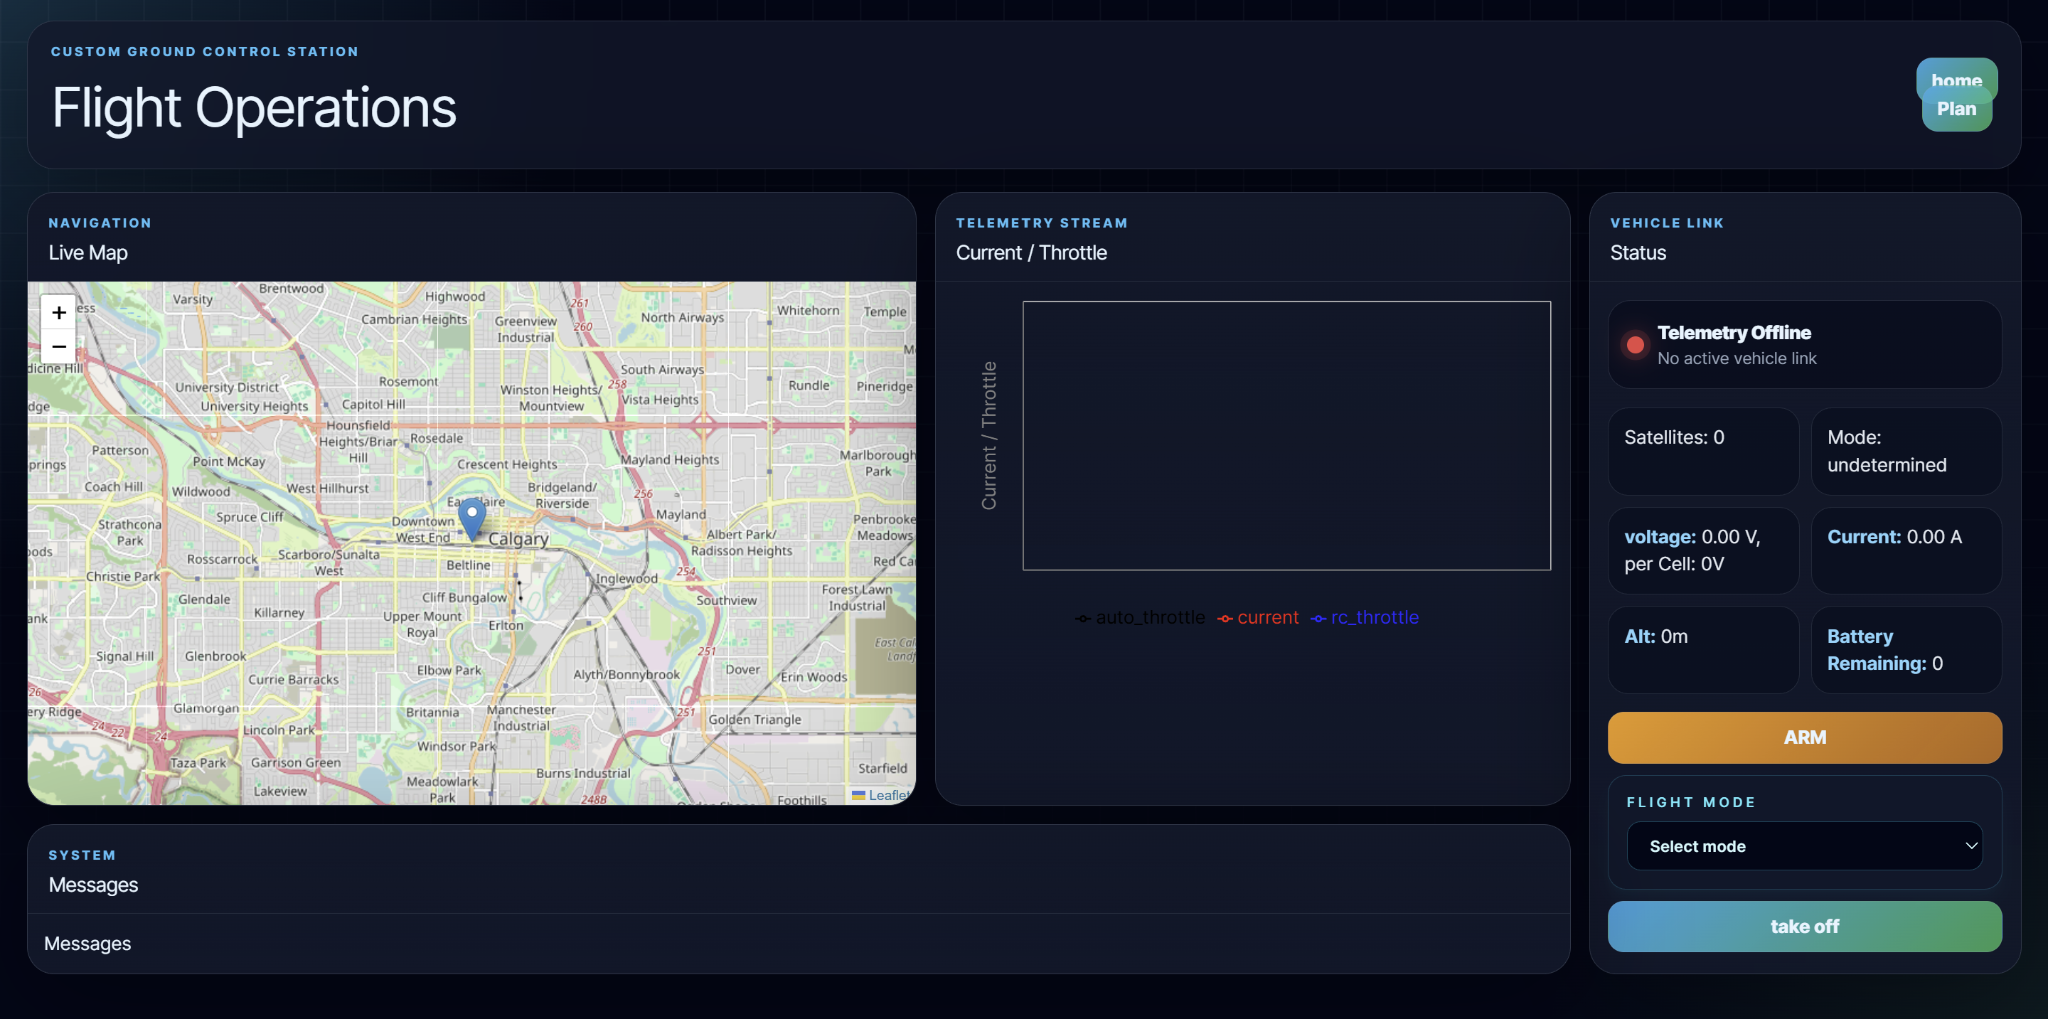
An ArduCopter aircraft with waypoint navigation, a custom web GCS for command and telemetry, live video, and purpose-built 6S1P Li-ion packs.
01
Objective
This project combined aircraft hardware, autonomous mission execution, a web-based operator interface, telemetry, live video, and custom battery fabrication into one end-to-end autonomous system.
02
My contribution
03
Design process
I developed the aircraft and operator interface together so real mission needs drove the UI and telemetry architecture. Flight testing was used to validate navigation, communications, video, and battery performance as a complete system.
04
Technical challenges
The design had to resolve these system-level and implementation requirements.
05
Validation or results
The system completed autonomous waypoint workflows while providing remote command, live telemetry, and video through the custom GCS.
06
Images and diagrams
Selected project photographs and design captures. Open any image to inspect it at full resolution.
07
Tools and technologies
ArduCopter · pymavlink · React · FastAPI · WebSockets