Embedded Systems · Completed
STM32 Bluetooth-Controlled RC Car
Embedded C firmware for a course-provided STM32 RC-car PCB, integrating Bluetooth commands with PWM motor and servo control, LED outputs, and ultrasonic sensing.
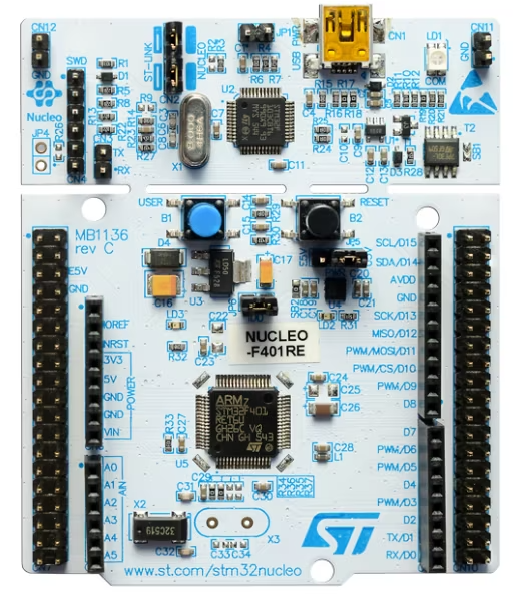
01
Objective
Developed embedded C firmware for an STM32-based RC car using a course-provided PCB. Implemented a UART Bluetooth command interface that translated wireless commands into real-time vehicle control. Integrated PWM motor-speed control, servo steering, LED outputs, and ultrasonic distance sensing. Debugged communication and peripheral-integration issues to achieve reliable end-to-end operation. The PCB was provided for the course; my primary contribution was firmware development, Bluetooth communication, peripheral integration, and debugging—not PCB design.
02
My contribution
03
Design process
I developed and tested each firmware-controlled function on the course-provided hardware, then integrated the UART command path with the vehicle outputs and sensor input. Debugging focused on communication behavior and interactions between the STM32 peripherals until the full control path operated reliably.
04
Technical challenges
This project integrated the following communication, control, sensing, and debugging requirements into one functioning system.
05
Validation or results
The finished firmware provided reliable end-to-end Bluetooth control of the RC car, including motor speed, servo steering, LED outputs, and ultrasonic distance sensing. The project demonstrates firmware and system-integration work on provided hardware; it does not represent a PCB design contribution.
06
Images and diagrams
Selected project photographs and design captures. Open any image to inspect it at full resolution.
07
Tools and technologies
STM32 · Embedded C · UART · PWM · Bluetooth · Ultrasonic Sensors · Motor Control